

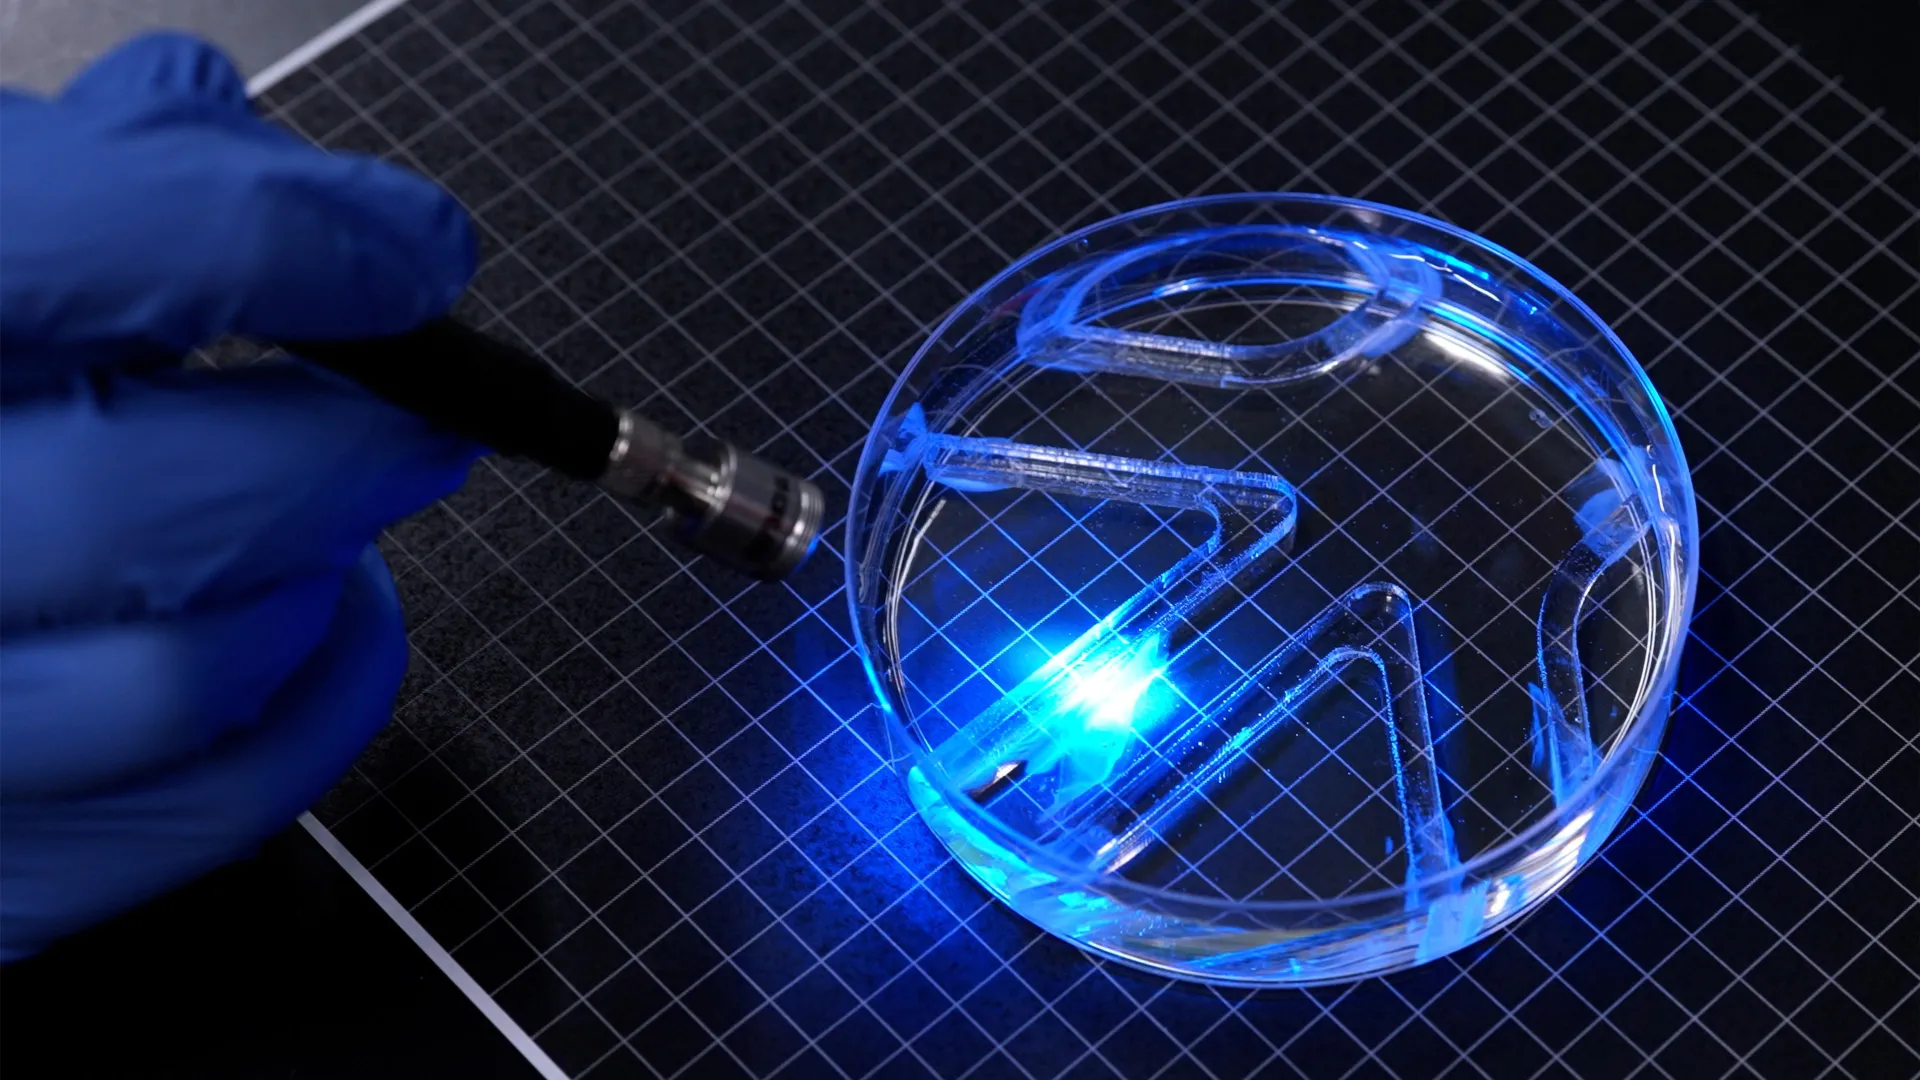
Researchers at MIT have developed a novel swimming robot that relies on living muscle tissue as its primary means of propulsion. The device features a flexible gel framework approximately the size of a stick of gum and incorporates two fins, each coated with an extremely thin layer of muscle cells. These cells have been genetically engineered to contract in response to light exposure, allowing the team to direct the robot’s movement by controlling which fin receives illumination and the frequency of that exposure.
The robot successfully navigated through an underwater maze during testing, demonstrating practical maneuverability. At its maximum speed, the device traveled approximately four times its body length per minute, which researchers note is comparable to the leisurely swimming pace of certain deep-sea organisms, though considerably slower than human swimmers. According to Ritu Raman, associate professor of mechanical engineering at MIT, the robot generates substantial force relative to its diminutive size.
This project marks the first demonstration of a two-dimensional biohybrid robot capable of locomotion using living muscle tissue. Previous iterations by the team and others typically employed larger, three-dimensional structures composed of laboratory-grown skeletal muscle, which required millions of cells to produce. The new design offers potential advantages in manufacturing efficiency and movement capability. Researchers suggest that such muscle-powered robots could eventually perform specialized tasks in environments too delicate or unpredictable for conventional mechanical systems.
The development built upon earlier work by Raman’s group, which created an artificial muscle disk inspired by the human iris. That project demonstrated that thin layers of living cells could produce precisely controlled multidirectional movements when appropriately structured and illuminated. For the swimming robot, the team optimized several parameters of the supporting gel foundation, including its chemical composition, rigidity, and surface geometry. They determined that firmer supporting materials enabled better muscle cell alignment and stronger contractions, ultimately producing sufficient force for aquatic propulsion.
Article Attribution | Read More at Article Source
Article summary produced by Claude AI